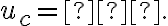Traction battery modeling
Abschlussbedingungen
1. Electrical properties and modeling
1.4. Parameter identification II
Determination of RC cell parameters
Thévenin models of first and second order
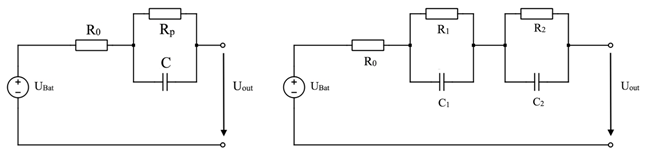
First vs. second order model
- The voltage stabilization transient does not correspond to a single exponential function → better modeled by a combination of two or more exponential functions.
- On the other hand,
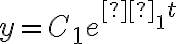 is an unambiguous problem => the dependence of R1 and C1 on T and SOC can be determined.
- Instead,
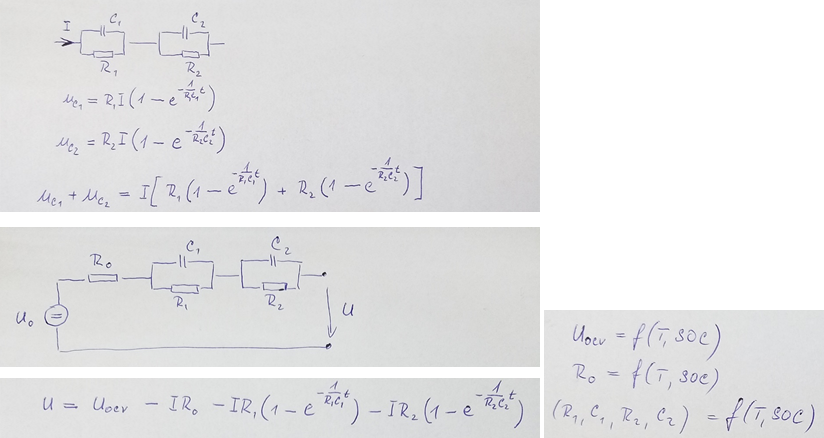
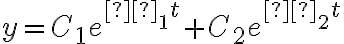 there is no unambiguous problem, ie. more combinations R1, C1, R2, C2 lead to the same curve => very problematic determination of dependence on T and SOC.
- However, the first-order model provides sufficient accuracy.
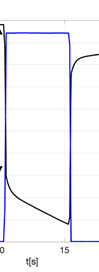
Derivation
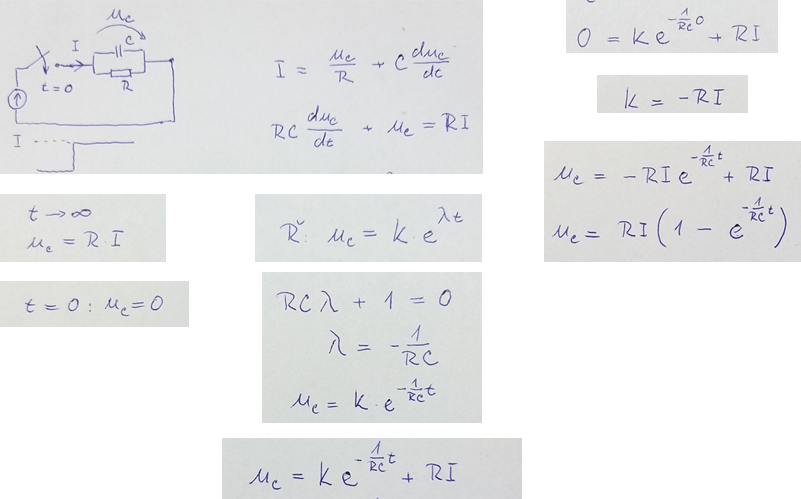
We derive the model for the RC cell by solving a first-order differential equation. Assume an RC cell to which we connect a constant current source I at time t = 0. We compile a differential equation where the total current I is divided into a current by a resistance Uc divided by R and a capacitor current, ie C duc according to dt. We convert the first-order differential equation into a standard form. We assume a general solution in the form 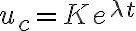 .
.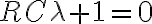 from where lambda equals -1 / RC and add it to the general solution.
For a particular solution, we use a steady state, where the voltage across the capacitor equals the resistance drop, i.e.
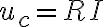 . So we get the solution
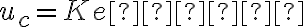
We determine the constant K using the state at time zero, when the voltage on the capacitor is equal to zero. Substituting into the equation we get the constant 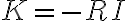 .
.Výsledné
řešení je tedy